Henrik I Christensen
Henrik I Christensen
Home
Posts
Projects
Courses
Students
Publications
Contact
CV
Light
Dark
Automatic
1
DexFLEX: Contact-Aware Foundation Controller for Command-Guided Dexterity
Dexterous robot hands can receive useful motion intent from teleoperation or learned policies, but successful execution also depends on …
Weikang Wan
,
Zeyu Lai
,
Jianyu Hou
,
Yuchen Zhou
,
Jiawei Fu
,
Henrik I Christensen
,
Hao Su
Cite
Code
Project
SafeDriveVLA: Navigation-Conditioned World Model Dreaming for Conflict-Aware End-to-End Autonomous Driving
Vision-Language-Action (VLA) models are gaining attention in autonomous driving, inheriting commonsense priors from large language …
Shaoyuan Xie
,
Zihan Zhang
,
Jingxuan Wang
,
Jiashu Qu
,
Xiaoqing Liang
,
Lingdong Kong
,
Junchi Lu
,
Henrik I Christensen
,
Qi Alfred Chen
Cite
Sensitivity Shaping for Latent Modeling
Generative dynamics models enable planning in challenging robotic systems, but safe deployment requires reliably detecting …
Hongzhan Yu
,
Chenghao Li
,
Ruipeng Zhang
,
Henrik I Christensen
,
Sicun Gao
Cite
FlashRFCL: Demonstration-Efficient Sparse Reward RL via Reverse-Forward Curriculum Learning in High-Throughput GPU Simulation
Solving complex tasks using reinforcement learning (RL) from sparse rewards and demonstrations is appealing since one can avoid reward …
Yong Woo Choi
,
Stone Tao
,
Henrik I Christensen
Cite
BridgeSim: Unveiling the OL-CL Gap in End-to-End Autonomous Driving
Open-loop (OL) to closed-loop (CL) gap (OL-CL gap) exists when OL-pretrained policies scoring high in OL evaluations fail to transfer …
Seth Z. Zhao
,
Luobin Wang
,
Hongwei Ruan
,
Yuxin Bao
,
Yilan Chen
,
Ziyang Leng
,
Abhijit Ravichandran
,
Honglin He
,
Zewei Zhou
,
Xu Han
,
Abhishek Peri
,
Zhiyu Huang
,
Pranav Desai
,
Henrik I Christensen
,
Jiaqi Ma
,
Bolei Zhou
Cite
Project
Cross-Embodiment Robot Intelligence
Robot embodiments are neither singular nor static. They differ across hardware designs, sensor configurations, and manufacturing …
Bo Ai
,
Henrik I. Christensen
,
Hao Su
Cite
Scaling Cross-Embodiment World Models for Dexterous Manipulation
Cross-embodiment learning seeks to build generalist robots that operate across diverse morphologies, but differences in action spaces …
Zihao He
,
Bo Ai
,
Tongzhou Mu
,
Yulin Liu
,
Weikang Wan
,
Jiawei Fu
,
Yilun Du
,
Henrik I. Christensen
,
And Hao Su
PDF
Cite
Enhancing Generalization in Vision–Language–Action Models by Preserving Pretrained Representations
Vision–language–action (VLA) models finetuned from vision–language models (VLMs) hold the promise of leveraging rich pretrained …
Shresth Grover
,
Akshay Gopalkrishnan
,
Bo Ai
,
Henrik I. Christensen
,
Hao Su
,
And Xuanlin Li
PDF
Cite
Code
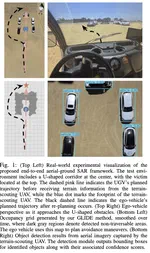
GLIDE: A Coordinated Aerial-Ground Framework for Search and Rescue in Unknown Environments
We present a cooperative aerial-ground search-and-rescue (SAR) framework that pairs two unmanned aerial vehicles (UAVs) with an …
Seth Farrell
,
Chenghao Li
,
Henrik I Christensen
PDF
Cite
Project
DOI
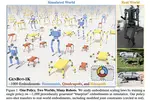
Towards Embodiment Scaling Laws in Robot Locomotion
Cross-embodiment generalization underpins the vision of building generalist embodied agents for any robot, yet its enabling factors …
Bo Ai
,
Liu Dai
,
Nico Bohlinger
,
Dichen Li
,
Tongzhou Mu
,
Zhanxin Wu
,
Kehlani Fay
,
Henrik I Christensen
,
Jan Peters
,
Hao Su
PDF
Cite
DOI
»
Cite
×